Co-founder, Exergy Motion
Building the machine-agnostic online control layer for variable-load industrial equipment; 34% measured energy cut vs. stock on real hardware; $30K non-dilutive funding raised.
Apr 2026 → present
Boston, MA
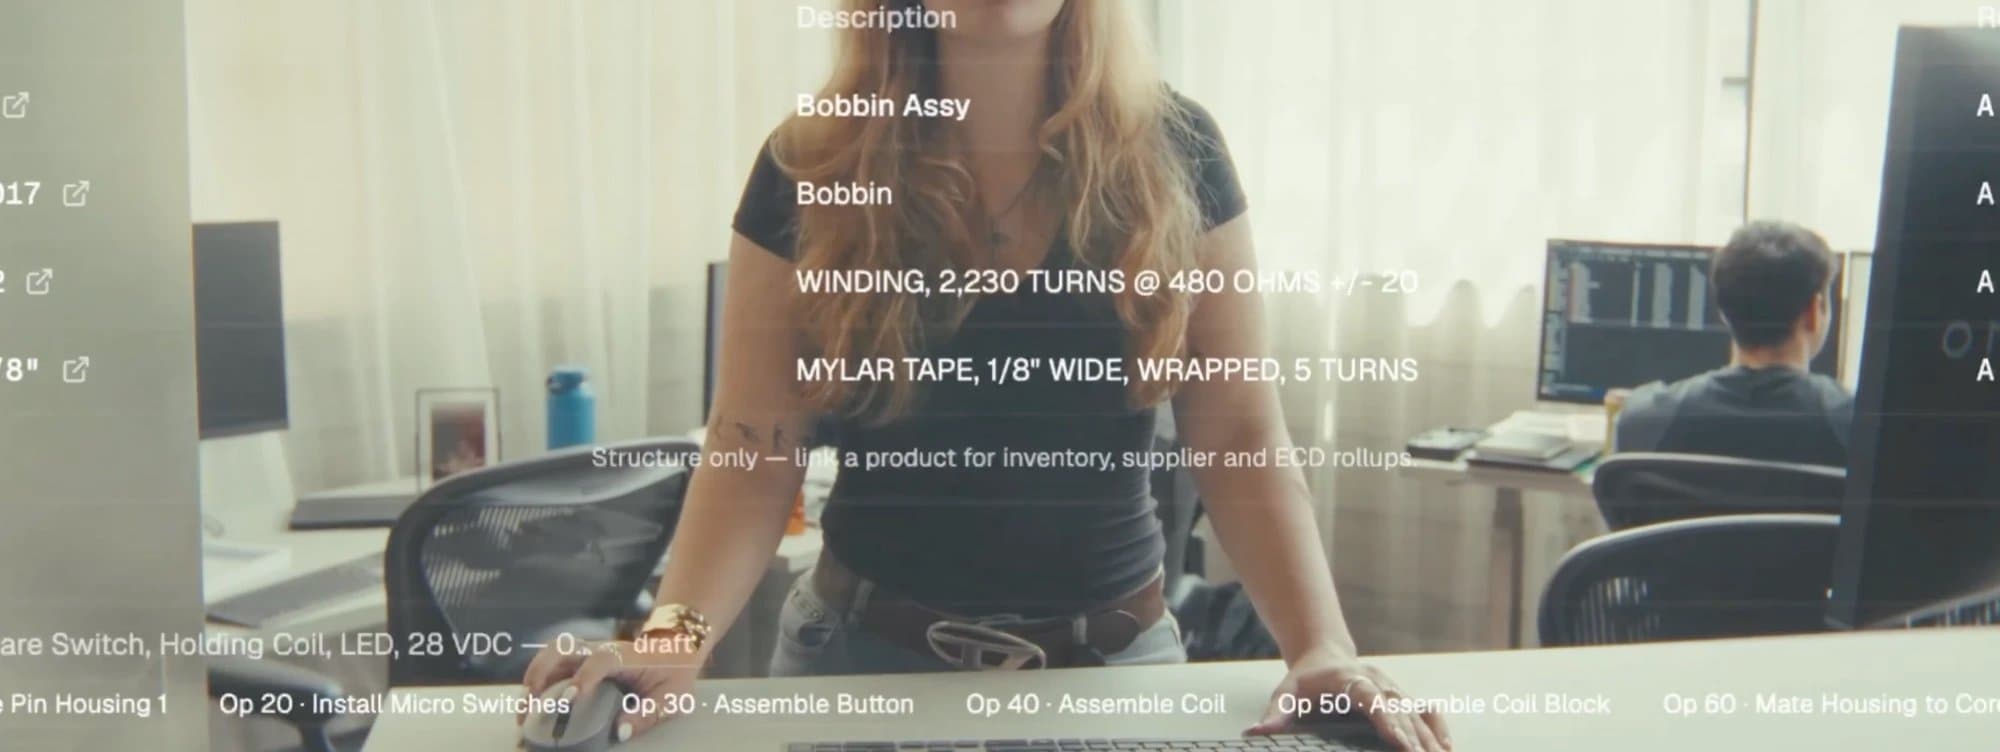
Building the machine-agnostic online control layer for variable-load industrial equipment; 34% measured energy cut vs. stock on real hardware; $30K non-dilutive funding raised.
Building the decision-theoretic planning layer over robotic field sampling; $5K non-dilutive funding raised; patent pending.
Built closed-loop control over lower-latency patch clamp electrophysiology hardware; $5K non-dilutive funding raised; acquired by enterprise pharma.
Full stack technical consulting from an iOS productivity app (top 40 on the app store) to ML models for a finance firm; scaled to 6 figures revenue; managed 13 contractors over 4 years in business.
I got my start in ML research at Northeastern's Plant Lab and Harvard Med's Bean Lab, building closed-loop systems that ran experiments on their own. That work pulled me toward the hardware itself, so I built (and sold) a venture in the field.
Now I'm at Amca owning the test infrastructure stack for autonomous hardware qualification, and co-founding Exergy Motion, an online control layer for industrial equipment. Before that, Lila Sciences' driver and orchestration layer for lab robots. On the side, a patent-pending contamination-aware sampling venture.
Self-designed my B.S. at Northeastern (CS + Physics, concentrations in Robotics and Biochem) as a full-ride Stamps Scholar; pursuing my M.S. in Robotics in parallel under Hanumant Singh.